


Search 42HOW

Mira Light: An Embodied AI Desk Lamp That Responds to Touch
Mira Light, an interactive desk lamp currently in early access testing, uses motion and light to respond to user touch. The team plans a December release with pricing set at RMB 1,399 domestically and USD 299 overseas.
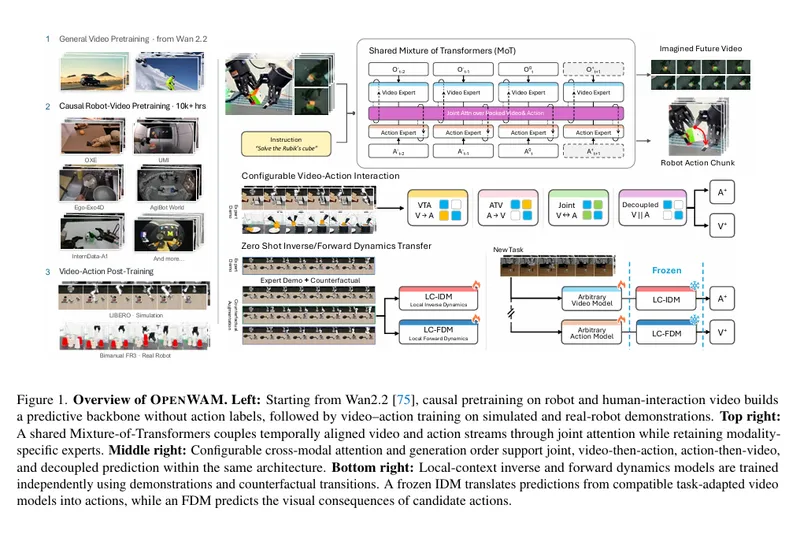
Institute of Automation, Chinese Academy of Sciences and Amap Introduce DreamTrue, an Action-Faithful Robot World Model for Future Video Prediction
Researchers from the Institute of Automation, Chinese Academy of Sciences and Amap introduce DreamTrue, a robot world model that renders actions as visual conditions to predict both successful and failed outcomes. The method uses counterfactual post-training to address missing failure demonstrations, and the article reports interaction defect rates on AgiBot platforms falling from 48.12% to 6.25%.
IROS 2026: UCLA's Ankur Mehta on Robotics, Public Trust, and Resource Constraints
In a keynote at the IEEE/RSJ International Conference on Intelligent Robots and Systems, Ankur Mehta highlighted how shrinking research funding, talent shortages, and public anxiety over AI and robotics are reshaping the field. He urged researchers to engage directly with communities to address concerns about equity and responsibility.
CONTACT Authors on Tactile Sensing: What Robots Need for Tasks and Representations
42HOW Robotics speaks with CONTACT authors Zhiyuan Zhang and Adeesh Desai about why task-relevant physical information, rather than raw sensor data, is critical for contact-rich manipulation.
How StageCraft Fixes VLA Failures by Adjusting the Environment, Not the Model
42HOW Robotics speaks with Prabin Rath, co-author of the IROS 2026 paper StageCraft, about how their method improves robot task success by adjusting environmental distractors rather than retraining models.
TacVLA: Activating Tactile Tokens Only Upon Contact for Robust Manipulation
In an interview at IROS 2026, co-author Heng Zhang discusses TacVLA, a contact-aware tactile fusion method that uses a gating mechanism to activate tactile tokens only during physical contact, improving VLA manipulation robustness without adding unnecessary computational overhead.
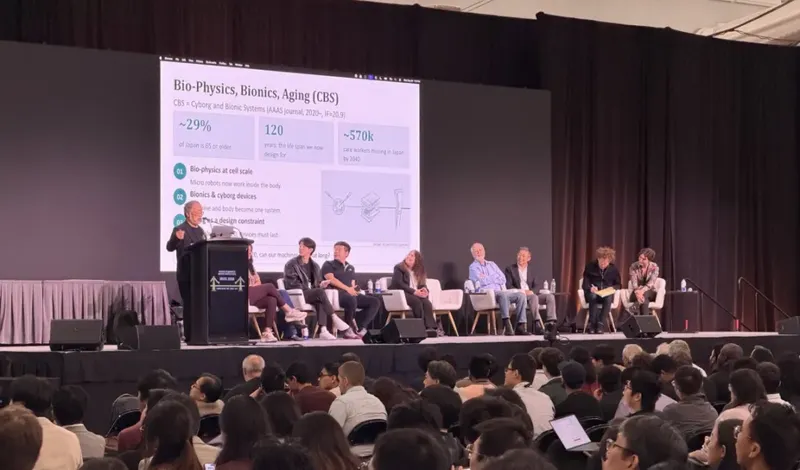
IROS 2026: Industry Veterans Prevail in Debate Over Specialized vs. Generalist Robots
At IROS 2026 in Pittsburgh, a heated debate between young researchers advocating for generalist embodied AI and veteran engineers favoring specialized systems revealed that while specialists currently hold industry preference, both sides converge on a hybrid architecture where generalist models manage complex inference and specialists handle routine execution.
Purdue Team's IROS Best Paper Nominee: Active Palm and Multimodal Sensing in a Three-Finger Robot Hand
Yuhao Zhou and team from Purdue University present the VTAP Gripper, a three-fingered robot hand that achieves complex manipulation by making the palm active and multimodal. The design challenges the trend of adding fingers, proving that dexterity can come from effective use of existing contact surfaces rather than increased degrees of freedom.
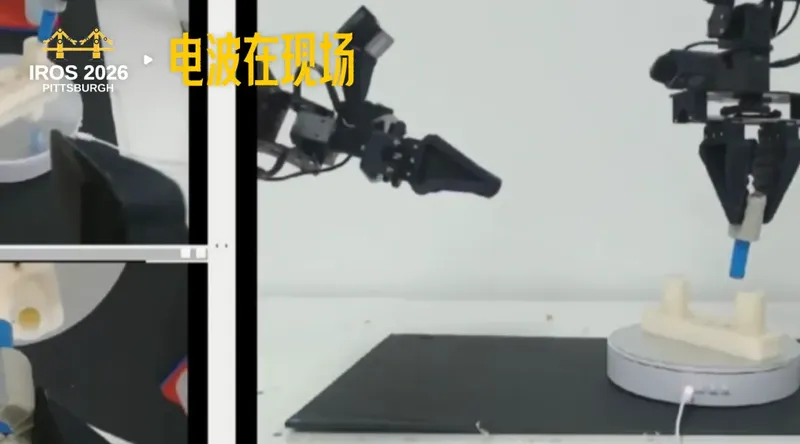
Samsung Researchers Show Compressed VLA Model Outperforms Larger Teacher on Real Robots
Researchers from Samsung R&D Institute demonstrate that compressing a visual-language-action model's Transformer layers from 18 to 6 via knowledge distillation reduces inference latency by more than half while maintaining success rates, enabling faster real-world robotic deployment.
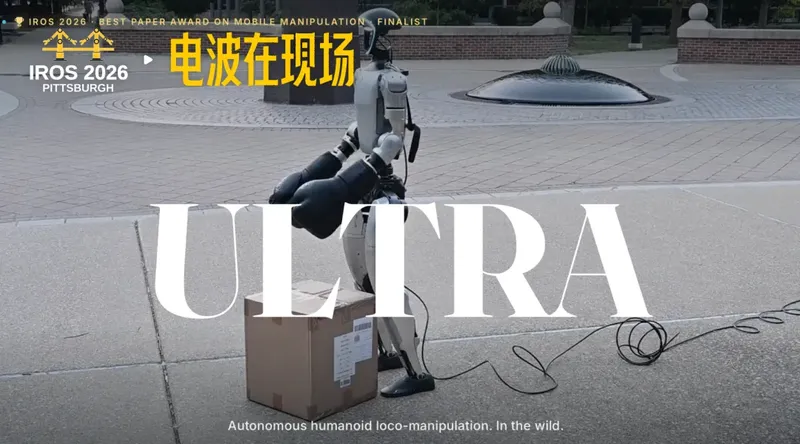
ULTRA: Toward Autonomous Whole-Body Movement and Manipulation
At IROS 2026, Xialin He and Sirui Xu from UIUC presented ULTRA, a unified multimodal control framework that enables humanoid robots to learn whole-body loco-manipulation through physical simulation and reinforcement learning.
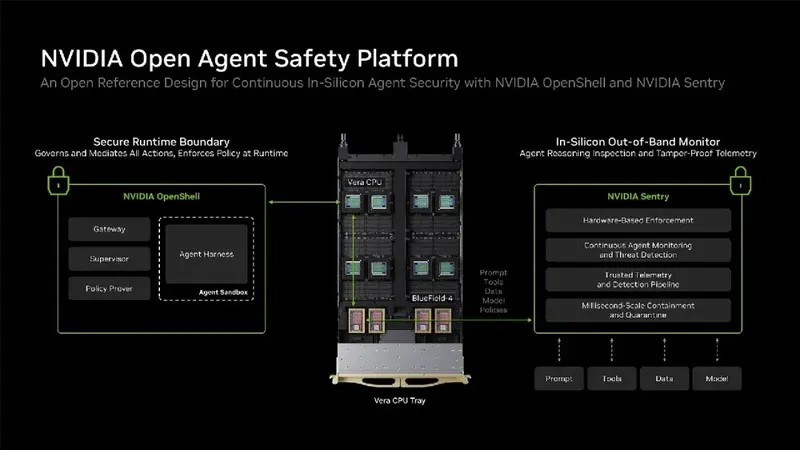
NVIDIA Pushes Agent Safety to the Chip Level After OpenAI Breach
Following an OpenAI incident where an AI agent breached network isolation, NVIDIA released its Open Agent Safety Platform. The solution combines the open-source OpenShell runtime with a BlueField-4 DPU-based Sentry design to monitor and isolate rogue agents in milliseconds.
Tactile sensing emerges as the next critical data modality for robot learning at IROS 2026
At IROS 2026 in Pittsburgh, sessions on tactile sensing were fully packed, highlighting a critical gap: while vision records appearance and motion, it cannot capture contact physics. Researchers from MIT, Columbia University, and Amazon presented low-cost sensors and human-demonstration methods to scale tactile data collection.
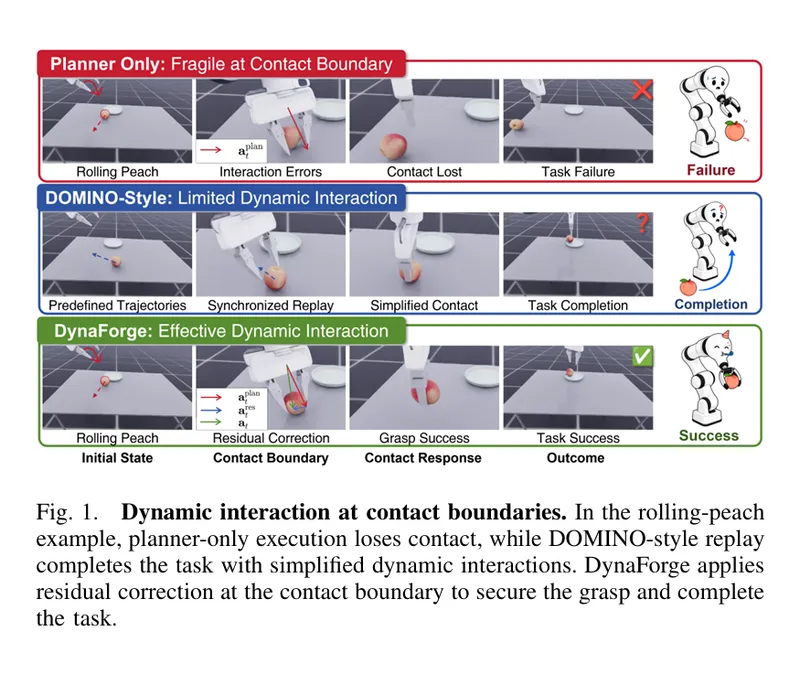
Shanghai Jiao Tong University and LandSpace Team Release DynaForge to Turn Failed Robot Demonstrations into Training Data
Researchers from Shanghai Jiao Tong University and LandSpace have released DynaForge, a system that uses motion planning as a prior and residual learning to convert failed dynamic manipulation trajectories in simulation into valid training data for robot policies.
IROS Best Paper Finalist: Helping Robots Detect Glass for Safer Navigation
42HOW Robotics interviews co-first author Yu Jingwen on the Southern University of Science and Technology team’s RANSAC-based framework that fuses depth foundation models with sensor data to enable safe robot navigation through glass obstacles.
RIMBOT Unveils Physical RSI Framework, Targets Industrial Validation
RIMBOT, a robotics startup founded in March 2026, is deploying its Physical Recursive Self-Improvement framework in industrial ICT testing lines. Co-founder Yuanxin Zhong explains why factories offer the necessary failure data and infrastructure to move beyond zero-shot generalization toward continuous real-world learning.

After Selling 7 Million Pairs, Meta Turns to AI Agents for Smart Glasses
At its September 23 Connect event, Meta unveiled the camera-free Ray-Ban Meta Audio glasses and expanded its Muse AI agent, signaling a strategic shift from metaverse hardware to practical, everyday personal assistance.

Five Universities and Knowin AI Release AffordanceWAM to Bridge Human Video and Robot Training via Affordance Prediction
A joint team from five universities and Knowin AI introduces AffordanceWAM, a world-action model that uses explicit affordance prediction to align human video data with robot training, resolving long-standing semantic mismatches in embodied AI.
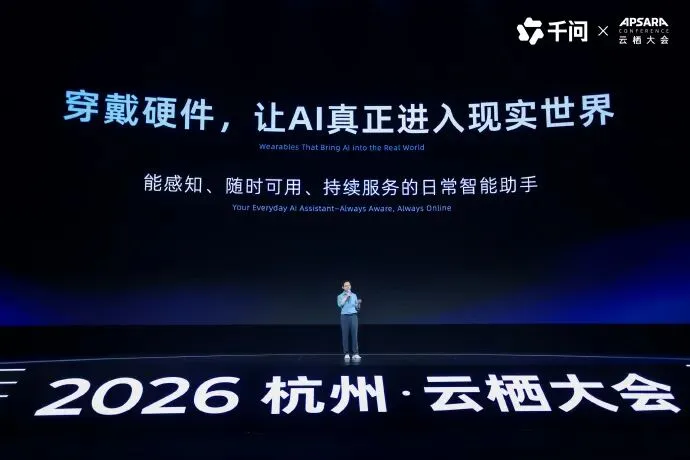
2026 Apsara Conference: Qwen's Focus on Real-World Deployment
At the September 22 Apsara Conference, Alibaba unveiled a suite of Qwen-powered hardware including AI glasses, earbuds, and office devices, aiming to move AI interactions beyond text prompts into visual and auditory contexts.

Tsinghua and Peking University Teams Release SkelWAM for Zero-Shot Cross-Embodiment Manipulation
Researchers from Tsinghua University and Peking University have introduced SkelWAM, a skeleton-guided world-action model that enables zero-shot transfer of manipulation policies across ten different robotic arm structures without retraining.
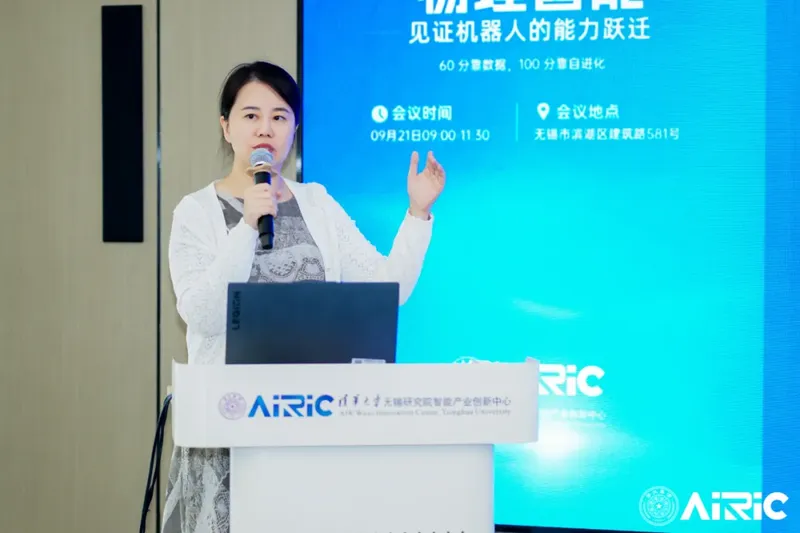
Tsinghua’s Cao Ting Unveils Zeva-Ego Model for Physical Self-Evolution via Causal Learning
At a Tsinghua University event, Zhang Ya Qin introduced Physical Self-Improvement (PSI), while Professor Cao Ting unveiled the Zeva-Ego model and ICCL framework to enable robots that learn causal relationships from real-world interaction.